Tag: Arduino

Printer disassembly + baby

A stop motion animation from my studio in Berlin 2011 where I disassemble and reuse old ink jet printers to construct new a series of kinetic artworks. Guest starring Joelle and four-month-old Sophia.
Fritzing for designing electronics

Fritzing logo

I just discovered Fritzing; an application for designing electronic projects and laying-out PCBs. The software is dependable, has a useful website with tutorials and project examples, and they are even starting a fabrication service in Dec 2010. Fritzing was started in August 2007 by the Interaction Design Lab at the University of Applied Sciences Potsdam, Germany.
Picture 12

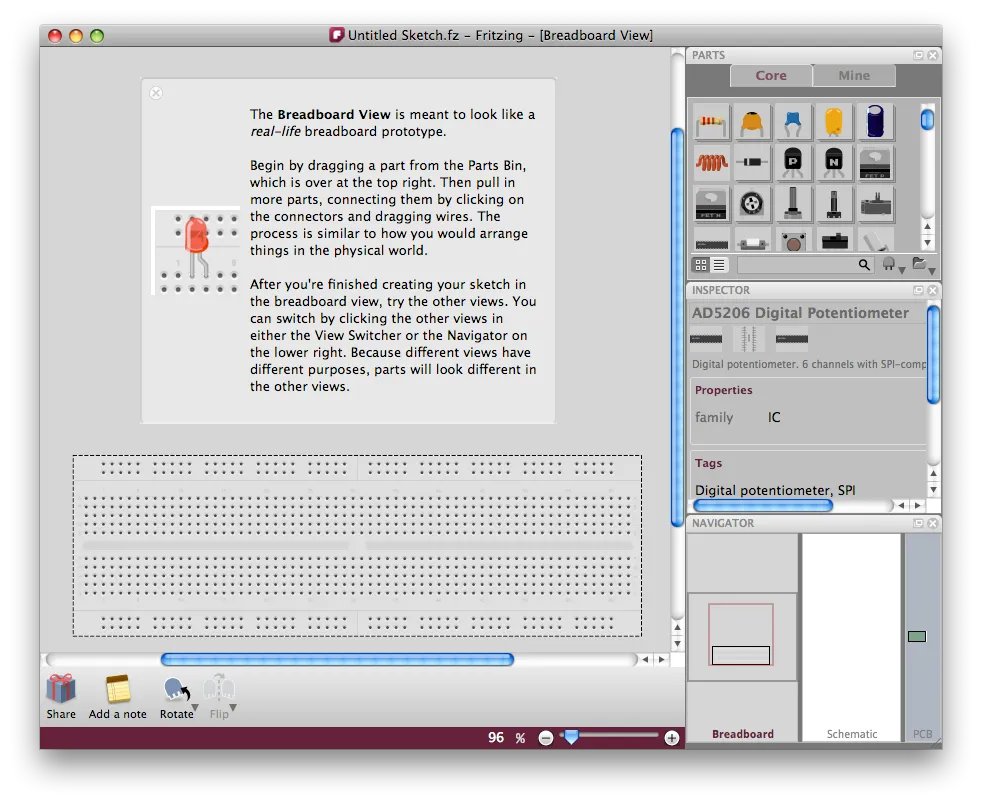
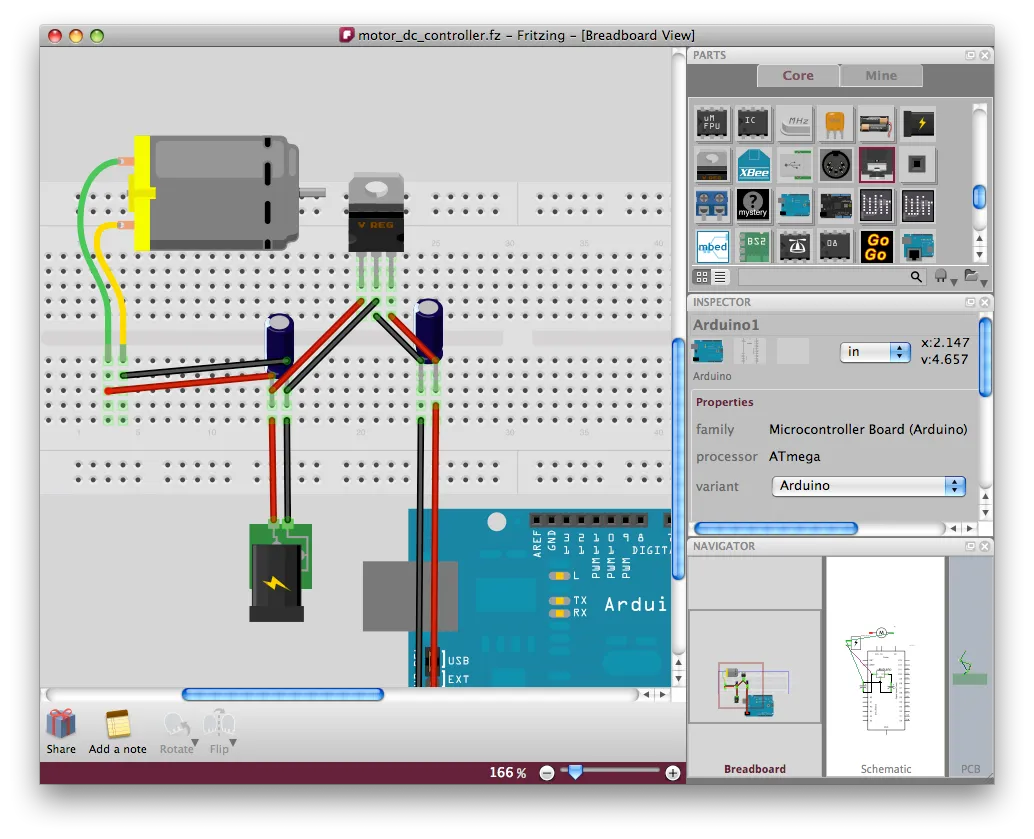
When you launch the software you begin with a breadboard. Then you drag components from a large list on the right, choosing options for the parts. Adjusting rotation, color, and placement is all fairly intuitive. While I found working with “2.5D” perspective is a little awkward at first, you get used to it. For output, you can select between Breadboard, Schematic, and PCB views on the bottom right.
Picture 17

Here’s a design to accompany a previous sketch, Fading an LED with PWM and a Potentiometer
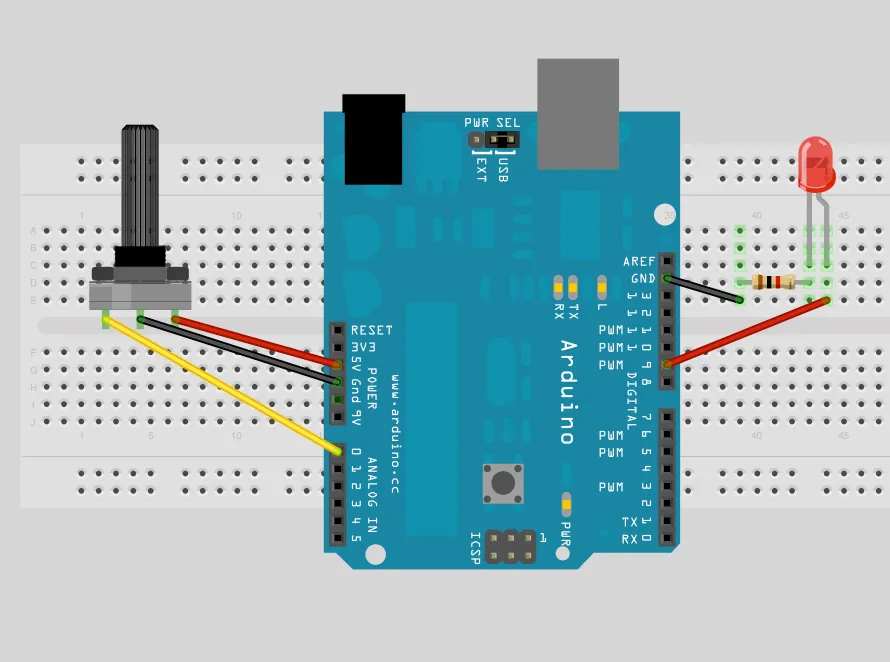
Diagram of a potentiometer wired to an LED

Schematic for You Never Close Your Eyes Anymore

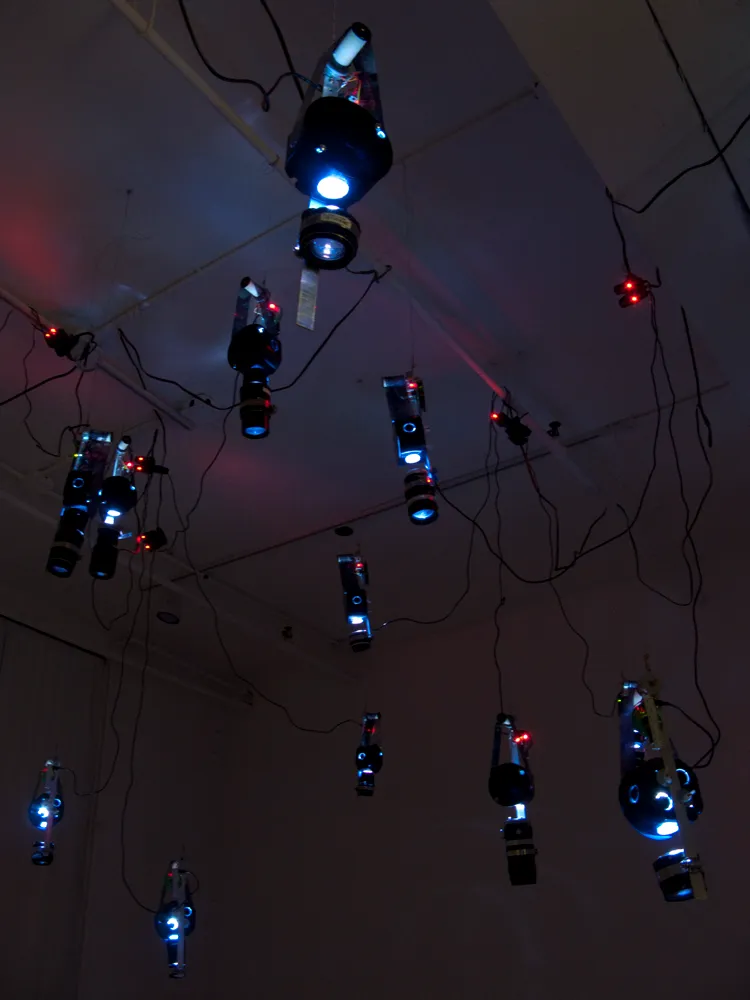
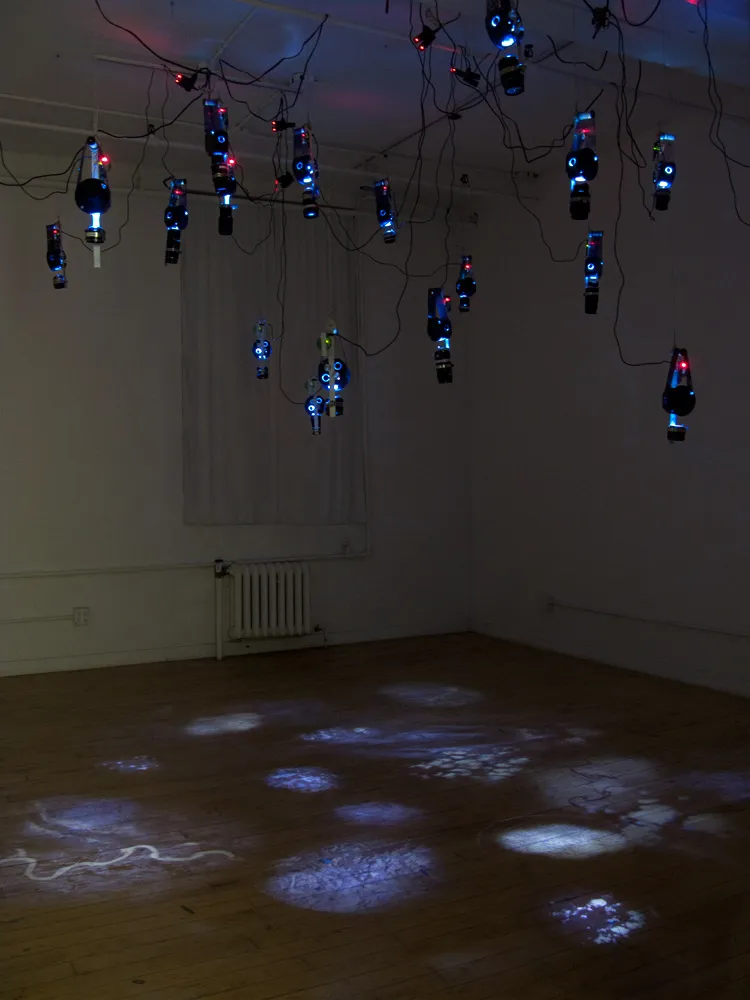
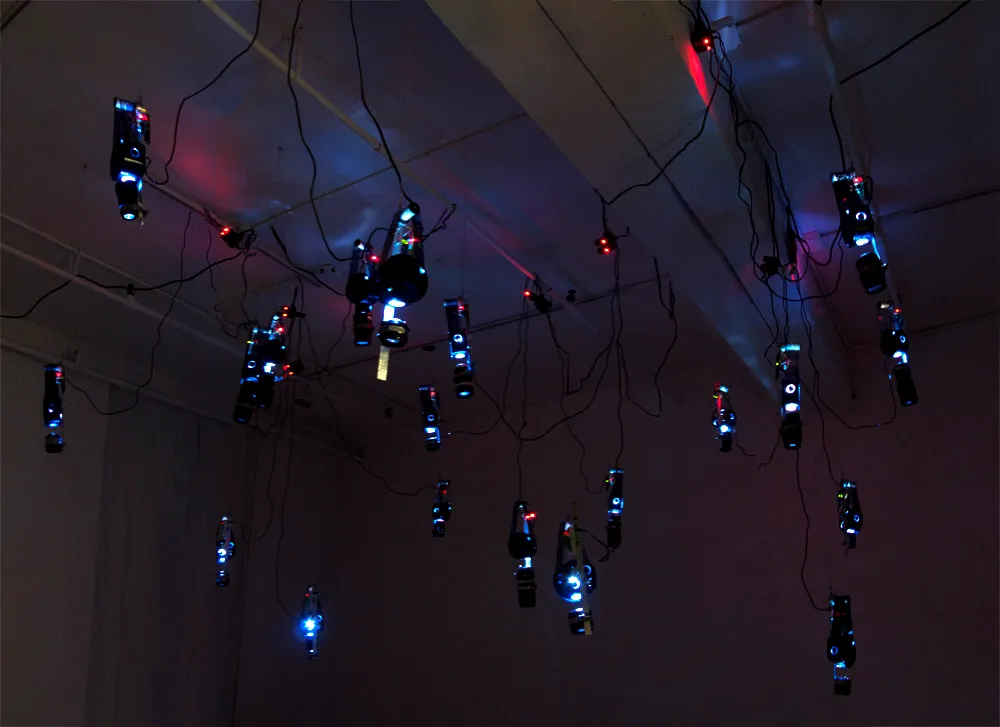
“Open sourcing” the schematic for the electronic components for You Never Close Your Eyes Anymore.
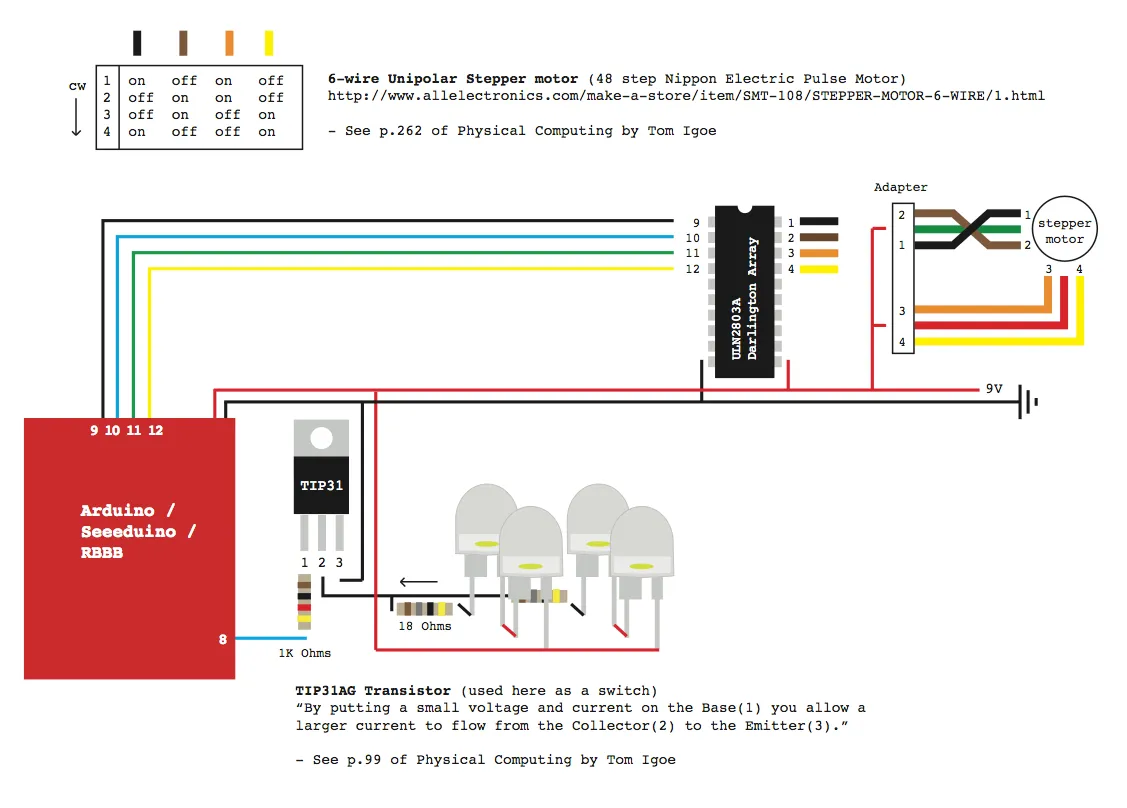
Picture 5

Products:

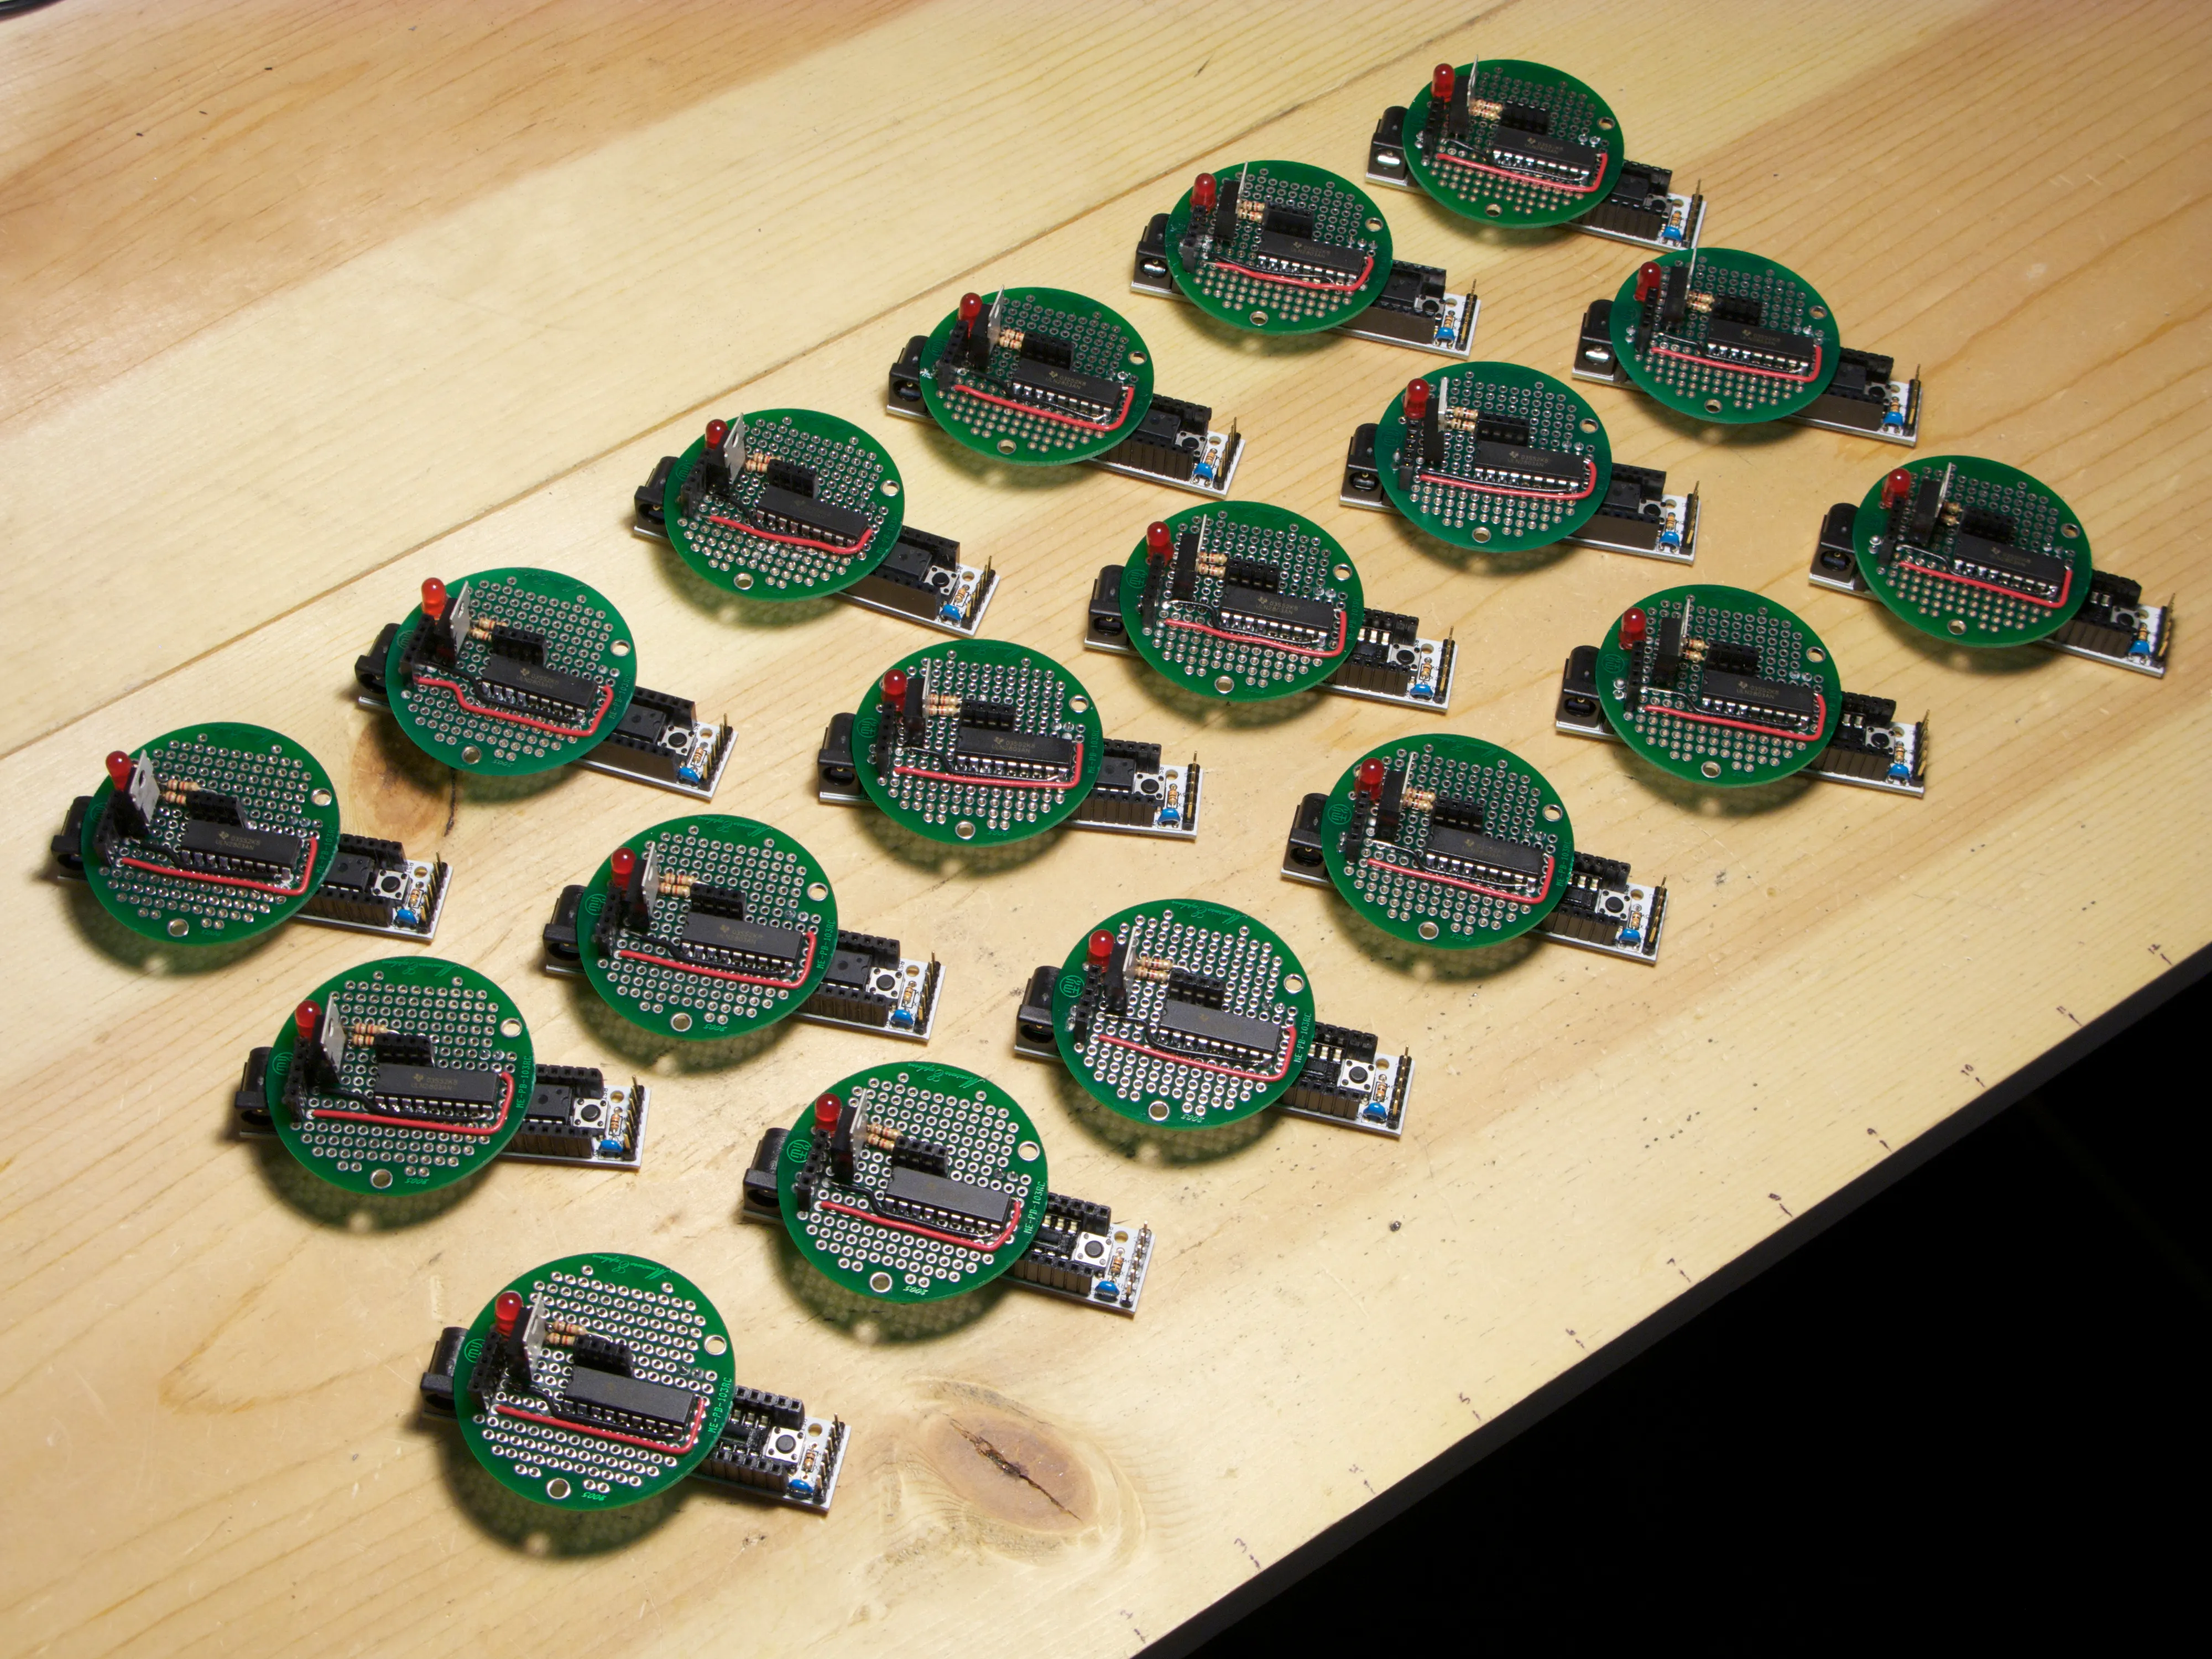
RBBB boards (Arduino clone)
custom-designed circuits
– female headers
– TIP31 transistor
– 6-wire Unipolar Stepper motor (48 step Nippon Electric Pulse Motor)
– ULN2803A Darlington Array
– hook-up wire
– various resistors
– LEDs
used camera lenses
aluminum “flat bar”
hose clamps
rubber wine corks
various mounting hardware

Fading an LED with PWM and a Potentiometer

Using a potentiometer and PWM on an Arduino to fade an LED.

  1. /* POT to LED test -> by Owen Mundy March 11, 2010
  2. from: http://itp.nyu.edu/physcomp/Labs/AnalogIn
  3. —————————————————————*/
  4. int potPin = 0; // Analog input pin that the potentiometer is attached to
  5. int potValue = 0; // value read from the pot
  6. int led = 9; // PWM pin that the LED is on. n.b. PWM 0 is on digital pin 9
  7. void setup() {
  8. // initialize serial communications at 9600 bps:
  9. Serial.begin(9600);
  10. // declare the led pin as an output:
  11. pinMode(led, OUTPUT);
  12. }
  13. void loop() {
  14. potValue = analogRead(potPin); // read the pot value
  15. analogWrite(led, potValue/4); // PWM the LED with the pot value (divided by 4 to fit in a byte)
  16. Serial.println("hello"); // print the pot value back to the debugger pane
  17. delay(10); // wait 10 milliseconds before the next loop
  18. }

Here is the schematic for the above project.

Diagram of a potentiometer wired to an LED

Using PWM and a potentiometer to fade an LED and drive a stepper motor, powered by a Boarduino RBBB.

  1. /*
  2. Owen Mundy
  3. July 29, 2009
  4. p. 262 of Physical Computing
  5. Using BBB to run stepper motor by manually moving steppers
  6. */
  7. int pin1 = 3; // PWM
  8. int pin2 = 5; // PWM
  9. int pin3 = 6; // PWM
  10. int pin4 = 9; // PWM
  11. int ledpin = 13; // LED
  12. int led = false; // LED monitor
  13. int motor_time_lapse = 80;
  14. int potPin = 0; // Analog input pin that the potentiometer is attached to
  15. int potValue = 0; // value read from the pot
  16. int ledPotPin = 11; // PWM pin that the LED is on. n.b. PWM 0 is on digital pin 9
  17. void setup()
  18. {
  19. pinMode(pin1, OUTPUT); // sets the pin as output
  20. pinMode(pin2, OUTPUT); // sets the pin as output
  21. pinMode(pin3, OUTPUT); // sets the pin as output
  22. pinMode(pin4, OUTPUT); // sets the pin as output
  23. pinMode(ledpin, OUTPUT); // sets the pin as output
  24. // initialize serial communications at 9600 bps:
  25. Serial.begin(9600);
  26. // declare the led pin as an output:
  27. pinMode(ledPotPin, OUTPUT);
  28. }
  29. void loop()
  30. {
  31. potValue = analogRead(potPin); // read the pot value
  32. analogWrite(ledPotPin, potValue/4); // PWM the LED with the pot value (divided by 4 to fit in a byte)
  33. Serial.println(potValue);
  34. digitalWrite(pin1, HIGH); // on
  35. digitalWrite(pin2, LOW); // off
  36. digitalWrite(pin3, HIGH); // on
  37. digitalWrite(pin4, LOW); // off
  38. delay(motor_time_lapse); // wait
  39. digitalWrite(pin1, LOW); // off
  40. digitalWrite(pin2, HIGH); // on
  41. digitalWrite(pin3, HIGH); // on
  42. digitalWrite(pin4, LOW); // off
  43. delay(motor_time_lapse); // wait
  44. digitalWrite(pin1, LOW); // off
  45. digitalWrite(pin2, HIGH); // on
  46. digitalWrite(pin3, LOW); // off
  47. digitalWrite(pin4, HIGH); // on
  48. delay(motor_time_lapse); // wait
  49. digitalWrite(pin1, HIGH); // on
  50. digitalWrite(pin2, LOW); // off
  51. digitalWrite(pin3, LOW); // off
  52. digitalWrite(pin4, HIGH); // on
  53. delay(motor_time_lapse); // wait
  54. blink();
  55. }
  56. void blink()
  57. {
  58. if (led == false)
  59. {
  60. led = true;
  61. digitalWrite(ledpin, HIGH); // on
  62. }
  63. else
  64. {
  65. led = false;
  66. digitalWrite(ledpin, LOW); // on
  67. }
  68. }

BBB (Freeduino) and stepper motor test

Test with BBB (Freeduino) board, Darlington H-Bridge, Mabuchi # PF35T-48L4 stepper motor. Many thanks to Tom Igoe and his Physical computing book.

  1. /*
  2. Owen Mundy
  3. July 29, 2009
  4. p. 262 of Physical Computing
  5. Using BBB to run stepper motor by manually moving steppers
  6. */
  7. int pin1 = 3; // PWM
  8. int pin2 = 5; // PWM
  9. int pin3 = 6; // PWM
  10. int pin4 = 9; // PWM
  11. int ledpin = 13; // LED
  12. void setup()
  13. {
  14. pinMode(pin1, OUTPUT); // sets the pin as output
  15. pinMode(pin2, OUTPUT); // sets the pin as output
  16. pinMode(pin3, OUTPUT); // sets the pin as output
  17. pinMode(pin4, OUTPUT); // sets the pin as output
  18. pinMode(ledpin, OUTPUT); // sets the pin as output
  19. }
  20. void loop()
  21. {
  22. for (int i=0; i<24; i++)
  23. {
  24. digitalWrite(pin1, HIGH); // on
  25. digitalWrite(pin2, LOW); // off
  26. digitalWrite(pin3, HIGH); // on
  27. digitalWrite(pin4, LOW); // off
  28. delay(10); // waits for a second
  29. digitalWrite(pin1, LOW); // off
  30. digitalWrite(pin2, HIGH); // on
  31. digitalWrite(pin3, HIGH); // on
  32. digitalWrite(pin4, LOW); // off
  33. delay(10); // waits for a second
  34. digitalWrite(pin1, LOW); // off
  35. digitalWrite(pin2, HIGH); // on
  36. digitalWrite(pin3, LOW); // off
  37. digitalWrite(pin4, HIGH); // on
  38. delay(10); // waits for a second
  39. digitalWrite(pin1, HIGH); // on
  40. digitalWrite(pin2, LOW); // off
  41. digitalWrite(pin3, LOW); // off
  42. digitalWrite(pin4, HIGH); // on
  43. delay(10); // waits for a second
  44. }
  45. blink();
  46. for (int i=0; i<24; i++)
  47. {
  48. digitalWrite(pin1, HIGH); // on
  49. digitalWrite(pin2, LOW); // off
  50. digitalWrite(pin3, LOW); // off
  51. digitalWrite(pin4, HIGH); // on
  52. delay(10); // waits for a second
  53. digitalWrite(pin1, LOW); // off
  54. digitalWrite(pin2, HIGH); // on
  55. digitalWrite(pin3, LOW); // off
  56. digitalWrite(pin4, HIGH); // on
  57. delay(10); // waits for a second
  58. digitalWrite(pin1, LOW); // off
  59. digitalWrite(pin2, HIGH); // on
  60. digitalWrite(pin3, HIGH); // on
  61. digitalWrite(pin4, LOW); // off
  62. delay(10); // waits for a second
  63. digitalWrite(pin1, HIGH); // on
  64. digitalWrite(pin2, LOW); // off
  65. digitalWrite(pin3, HIGH); // on
  66. digitalWrite(pin4, LOW); // off
  67. delay(10); // waits for a second
  68. }
  69. blink();
  70. for (int i=0; i<6; i++)
  71. {
  72. digitalWrite(pin1, HIGH); // on
  73. digitalWrite(pin2, LOW); // off
  74. digitalWrite(pin3, HIGH); // on
  75. digitalWrite(pin4, LOW); // off
  76. delay(10); // waits for a second
  77. digitalWrite(pin1, LOW); // off
  78. digitalWrite(pin2, HIGH); // on
  79. digitalWrite(pin3, HIGH); // on
  80. digitalWrite(pin4, LOW); // off
  81. delay(10); // waits for a second
  82. digitalWrite(pin1, LOW); // off
  83. digitalWrite(pin2, HIGH); // on
  84. digitalWrite(pin3, LOW); // off
  85. digitalWrite(pin4, HIGH); // on
  86. delay(10); // waits for a second
  87. digitalWrite(pin1, HIGH); // on
  88. digitalWrite(pin2, LOW); // off
  89. digitalWrite(pin3, LOW); // off
  90. digitalWrite(pin4, HIGH); // on
  91. delay(10); // waits for a second
  92. }
  93. blink();
  94. for (int i=0; i<6; i++)
  95. {
  96. digitalWrite(pin1, HIGH); // on
  97. digitalWrite(pin2, LOW); // off
  98. digitalWrite(pin3, LOW); // off
  99. digitalWrite(pin4, HIGH); // on
  100. delay(10); // waits for a second
  101. digitalWrite(pin1, LOW); // off
  102. digitalWrite(pin2, HIGH); // on
  103. digitalWrite(pin3, LOW); // off
  104. digitalWrite(pin4, HIGH); // on
  105. delay(10); // waits for a second
  106. digitalWrite(pin1, LOW); // off
  107. digitalWrite(pin2, HIGH); // on
  108. digitalWrite(pin3, HIGH); // on
  109. digitalWrite(pin4, LOW); // off
  110. delay(10); // waits for a second
  111. digitalWrite(pin1, HIGH); // on
  112. digitalWrite(pin2, LOW); // off
  113. digitalWrite(pin3, HIGH); // on
  114. digitalWrite(pin4, LOW); // off
  115. delay(10); // waits for a second
  116. }
  117. blink();
  118. }
  119. void blink()
  120. {
  121. digitalWrite(ledpin, HIGH); // on
  122. delay(1000); // waits for a second
  123. digitalWrite(ledpin, LOW); // off
  124. }